Robot spare-parts sourcing requirements and scope worksheet
Blank working rows with an explicitly illustrative example; no product specification or completed observation is prefilled.
Download worksheet ↓robopartspro.com
Compare drives, reducers, tooling and harnesses around your installed system. Bring a clear specification to your next supplier enquiry.
robopartspro.com
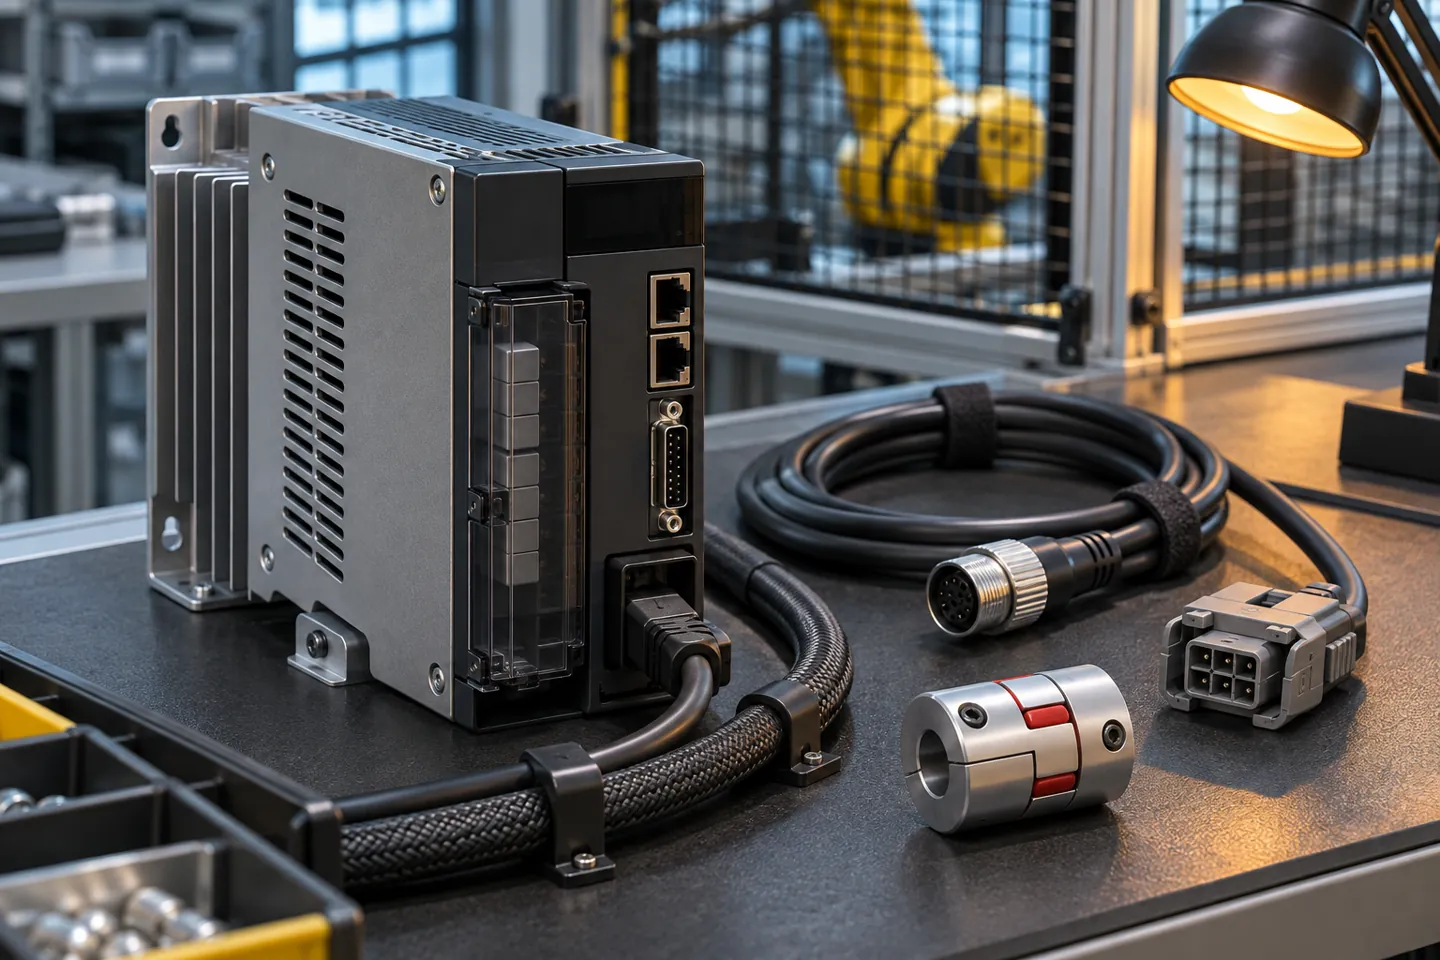
A drive belongs to a combination of motor, feedback device, controller, firmware and parameters.
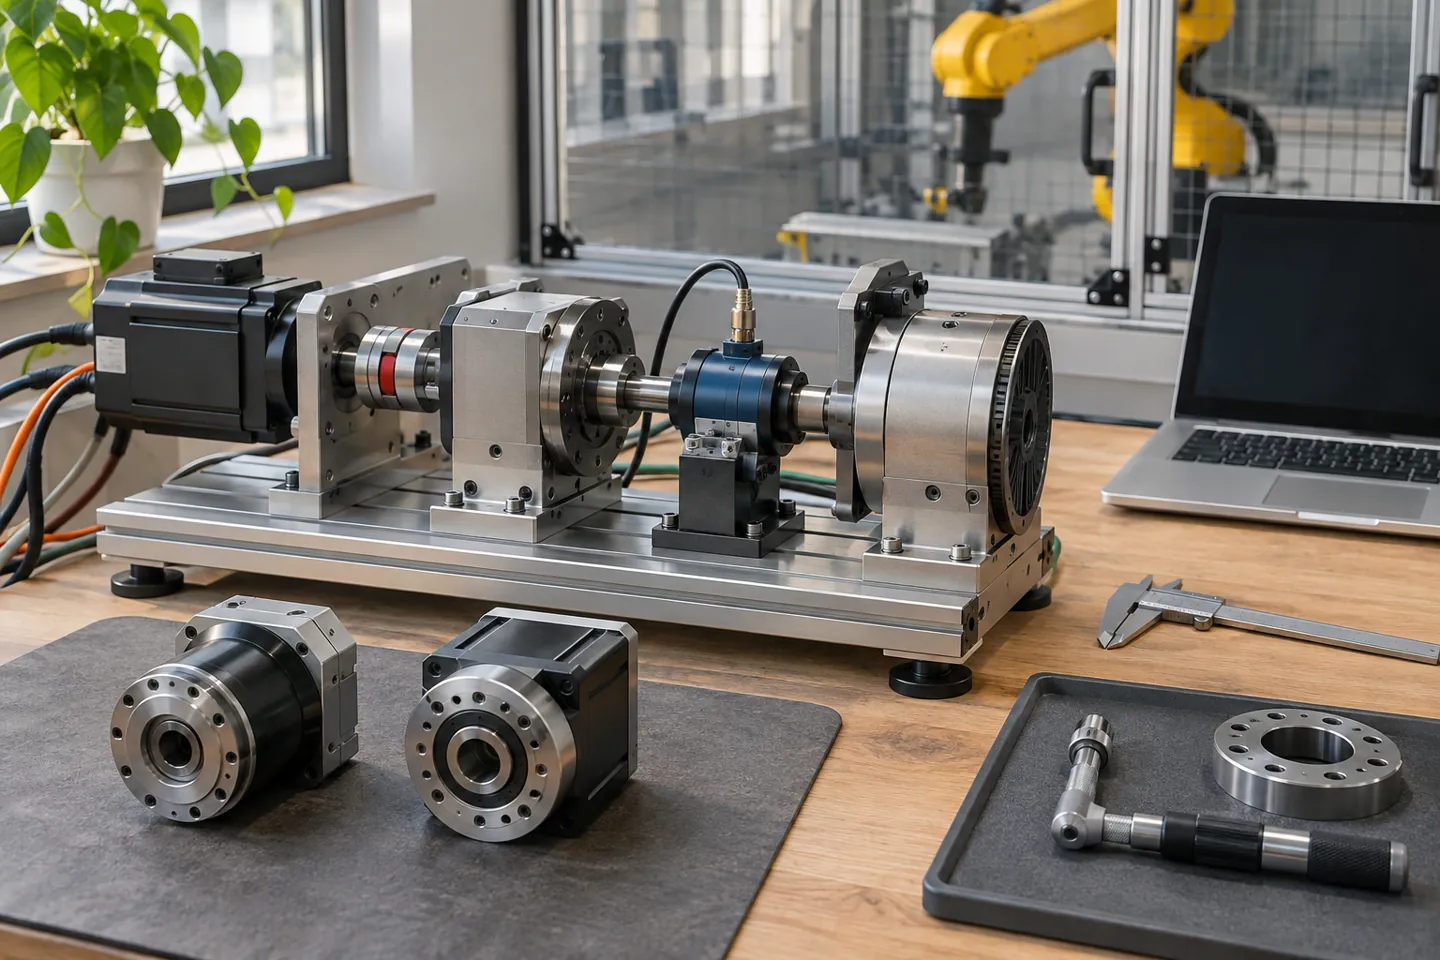
A reducer comparison should identify the torque condition, the measured end and the definition of the published number.
A tool replacement affects more than the flange.
A harness is a connection map and a moving assembly. Connector keying does not establish the pin assignment, and wire colour is not an approved pinout.
robopartspro.com
Blank working rows with an explicitly illustrative example; no product specification or completed observation is prefilled.
Download worksheet ↓Align task, evidence and scope before entering a real quotation or decision. UTF-8 tab-separated text.
Download worksheet ↓Record expected, actual, discrepancy and responsibility separately; illustrative rows are not completed tests.
Download worksheet ↓robopartspro.com
Compare drives, reducers, tooling and harnesses around your installed system. Bring a clear specification to your next supplier enquiry.
Servo drives:Capture labels and the original alarm timeline before clearing it.
Reducers:Keep the drawing revision and joint position with each enquiry.
End effectors:Provide object dimensions, material, contact restrictions and tool identity.
Cables and connectors:Photograph labels, routing and strain relief before removal.
robopartspro.com
A drive alarm occurs during a particular motion. Decide between a supported replacement and further diagnosis, then verify the original task.
EXERCISE / 02A laboratory changes a gripper and moving harness. Compare a verified replacement route with a new interface, retaining object and motion checks.
robopartspro.com
A drive-related alarm exists without a complete revision map.
View approach & inputs
A mating connector or flange is being treated as full compatibility.
View approach & inputs
The receiver lacks a clear task and observation boundary.
View approach & inputsrobopartspro.com
A useful maintenance dossier contains the original alarm text, controller time, task stage, tool state and the changes already attempted.
Create a revision-based compatibility dossier for drives, reducers, tooling and moving harnesses.
A buyer should commission a supported replacement decision rather than a part that merely looks similar. Start with the installed identity, the symptom and the required return-to-service task. Ask a quotation t
An application dossier should connect the original machine, the proposed component and the task that will demonstrate the intended result. The most useful plans are often narrower than a complete repair promise
Fault investigation should distinguish an observed alarm from an established failed component. Preserve the first deviation, the task and the installed revisions before selecting a replacement. A successful res
Maintenance information should keep the physical assembly, its permitted configuration and the observation history together. A new harness, feedback revision or tool adapter can change the relevant checks even
A substitute part should be selected by the relationships it must preserve. A drive, reducer, tool and harness each connects to the robot in a different way, so a single compatibility tick hides important quest
A handover should allow the receiving engineer to reconstruct the decision and continue the task. Preserve identities, revisions, permitted combinations, changed parameters, original observations and open condi
robopartspro.com