Hypothetical drive replacement dossier
Hypothetical application exercise: conditions, practical choices and review decisions; not a delivered customer project.
Task and implementation
Task and explicit assumptions
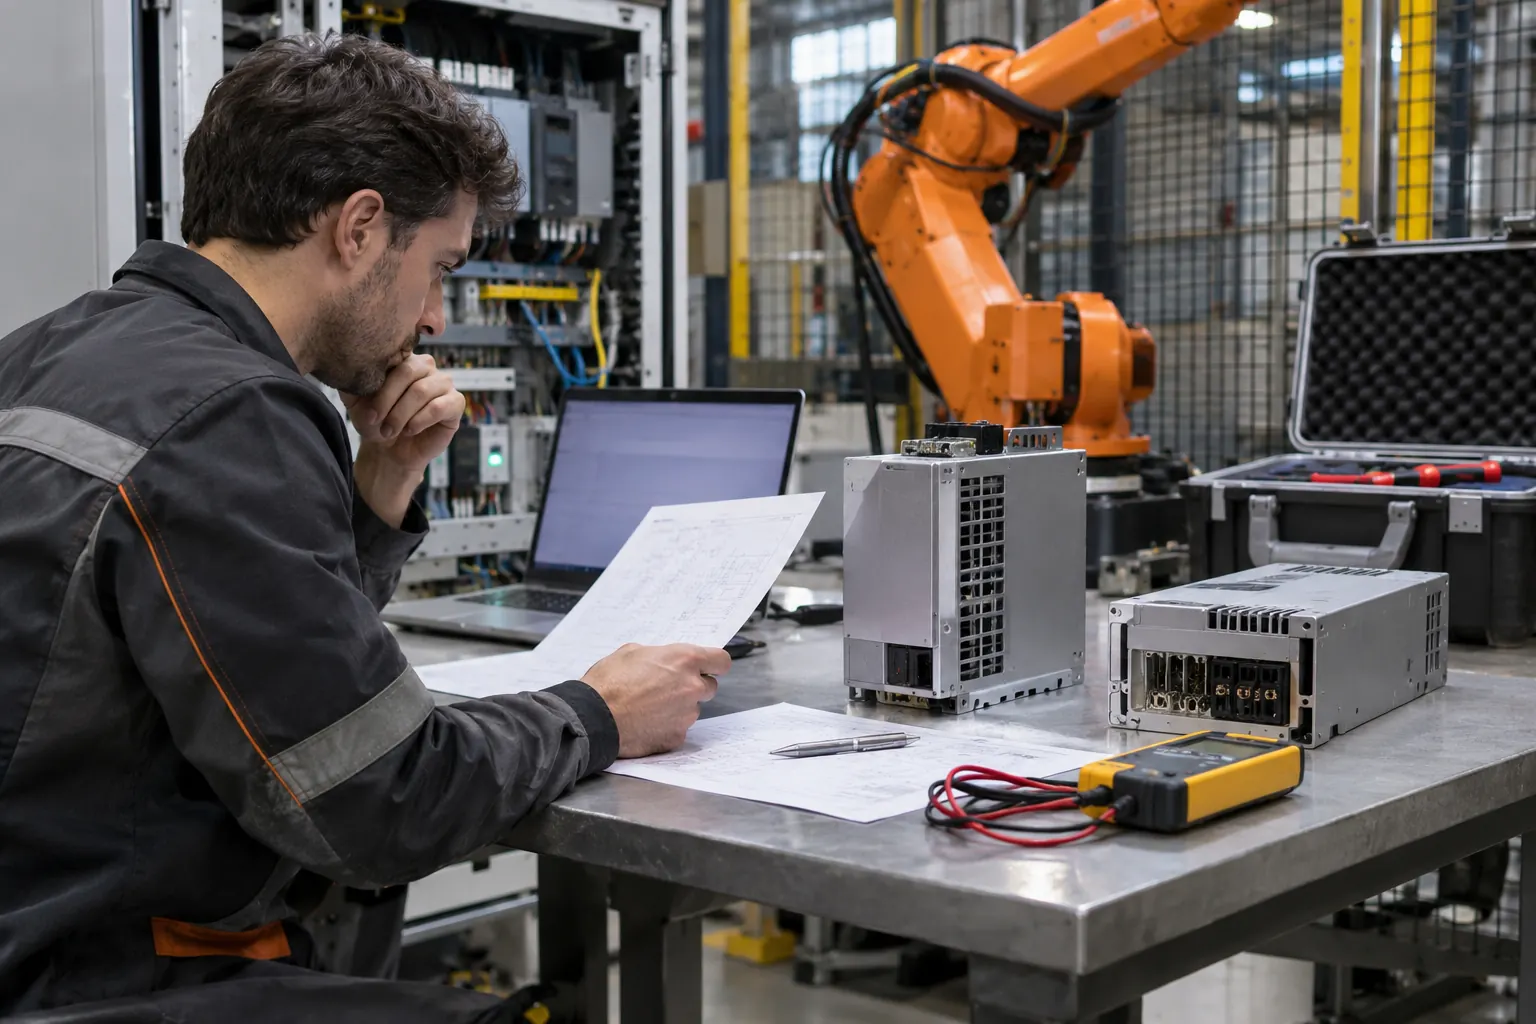
An integrator is assumed to have a robot that reports a drive-related alarm during a specific motion. Before asking for a replacement, the exercise collects the robot serial identity, controller and firmware, motor and feedback labels, installed drive revision and the original alarm timeline. The buyer also lists any parameter or harness changes already attempted. The task is to distinguish what is known about the failed configuration from what a proposed replacement would require. No actual customer, stock item or completed repair is represented.
Two routes and their tradeoffs
Route A is an exact or explicitly supported replacement after the installed combination and fault basis are known. It narrows configuration uncertainty but still requires permitted parameter handling and a task check. Route B is a bounded diagnosis before buying, appropriate when the alarm has not identified the failed assembly. It takes observation time but can prevent an unnecessary drive purchase. Neither route turns a mating connector or a cleared alarm into proof of compatibility or root cause.
A task-specific execution method
Preserve the alarm before clearing it. Align controller time, motion stage, tool, drive, motor and feedback identities. Separate original exports from operator recollection. Use the applicable equipment procedure to check the proposed combination, backup coverage and authorised restoration. Where the procedure allows a comparison, change one defined condition at a time. Retain failed and interrupted attempts, not only the final restart. If several changes cannot be separated, record the limit on attribution instead of choosing the most convenient explanation afterwards.
Worked hypothetical result and decision
Extend the exercise by assuming the original alarm appeared after about one hour of an ordinary repeated task, while the replacement has been observed for ten minutes. The result is only ten minutes without recurrence; it does not cover the original window. If an applicable task check later covers that condition, report its actual tool, motion and duration. If the symptom returns, return to diagnosis rather than repeatedly restarting. No deliberate overload, altered protection limit or forced fault is proposed to accelerate the observation.
Problem branches and stopping conditions
If controller support, feedback or the permitted parameter transfer is unconfirmed, the enquiry remains open and returns to the relevant maker or service party. If the combination is confirmed, the verification plan still needs the original triggering task and an observation window appropriate to it. The deliverable is a compatibility map, preserved logs, authorised change record and explicit unresolved items. One successful restart cannot close a fault that originally appeared only after longer operation, and the exercise never permits bypassing protection to force a result.
What the receiving team can conclude
The receiving engineer should obtain a decision that distinguishes identity, supported combination, intervention and observed outcome. An item received is not the same as a task restored. If the evidence supports only the replacement relationship, say so; if it also covers a task, state the task and window. Keep unknown thermal, motion or configuration conditions open. This preserves a useful result even when the correct choice is to defer purchase or postpone full release rather than announce a permanent repair.
A quotation should distinguish the component from diagnosis, permitted restoration and the observation after installation. If those scopes belong to different parties, name the handover between them. This makes a deferred decision useful rather than an unexplained refusal or an assumed repair.
Before you begin
1. Installed robot and drive identities
2. Original motion, alarm and revisions
3. Permitted restoration and task scope
Review criteria and sources
Review criteria
- Supported combination is explicit
- Observation covers stated task only
- Unknown cause remains visibly open
Primary-source reading
Harmonic Drive Engineering Data
https://www.harmonicdrive.net/_hd/content/documents1/FBB_DifferentialGear.pdf
UR-Series Service Manual
https://www.universal-robots.com/manuals/EN/PDF/Shared/service-manual_ur-series/Service_Manual_UR-Series_en.pdf
A useful conversation starts with a specific task.
Share your product, application, constraints and intended outcome.